ARMOR
Augmented Reality Mobile Robotics MuJoCo Physics on iOS+Mac
Screenshots
Video Demo
Freemium
3D Modeling
Augmented Reality
Mobile App
Built with Swift
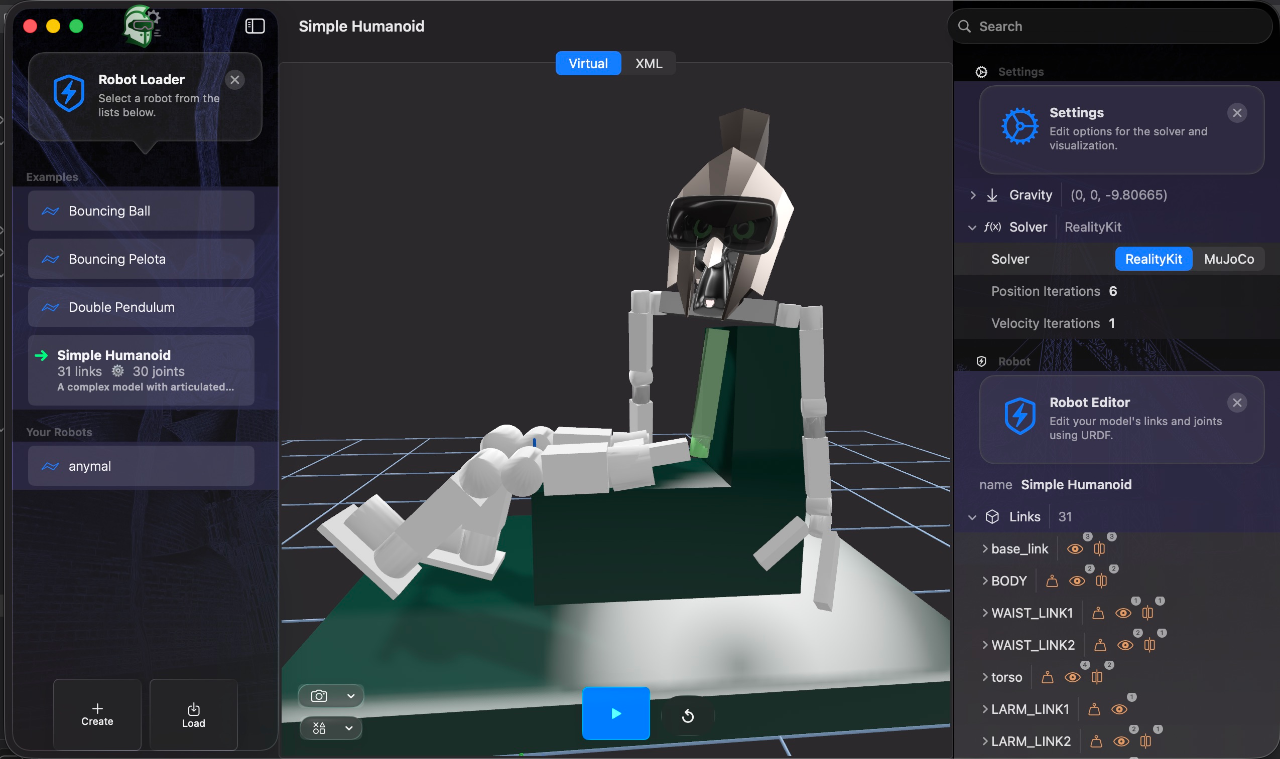
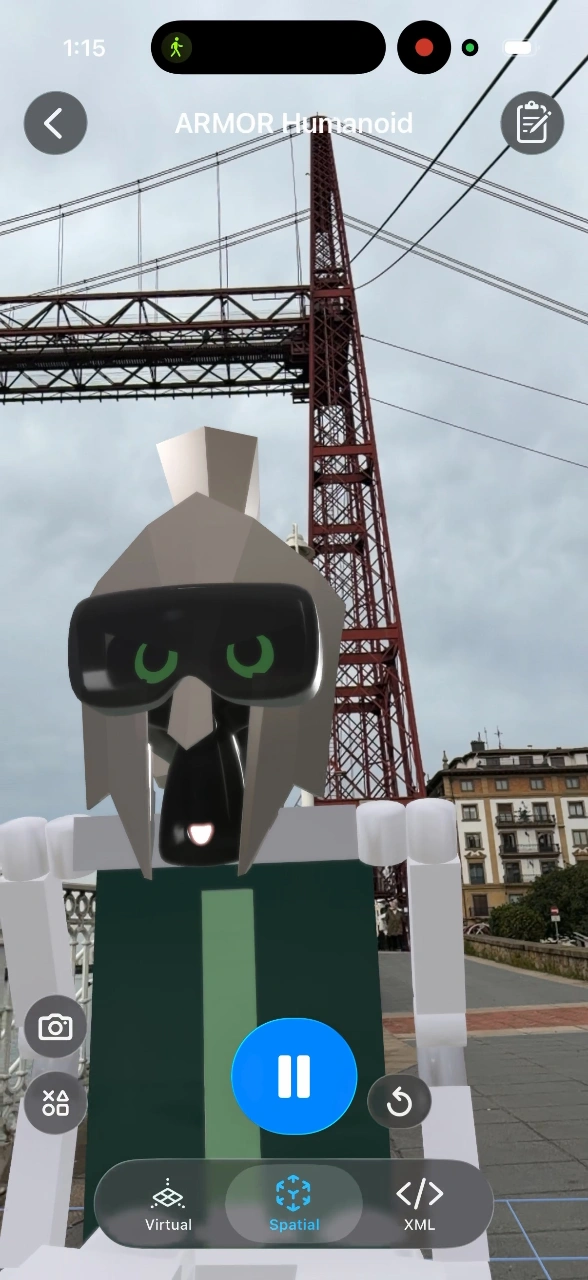
SwiftARMOR (Augmented Reality Mobile Robotics) is a SwiftUI app for iOS, iPadOS, and macOS that loads URDF robot models and simulates them with the MuJoCo physics engine (or RealityKit physics), with AR placement support.
Key Features
- Real MuJoCo physics (not a toy/approximate engine) running natively on-device
- Bridges desktop-grade simulation and mobile/AR accessibility — present, teach, or debug robotics work away from a workstation
- Full workflow: import/edit URDF → simulate → export back to ROS-style URDF package or MuJoCo MJCF for desktop continuation
- In-app Gallery of pre-made, ready-to-simulate robot models — removes the burden of sourcing or cleaning up a URDF file yourself
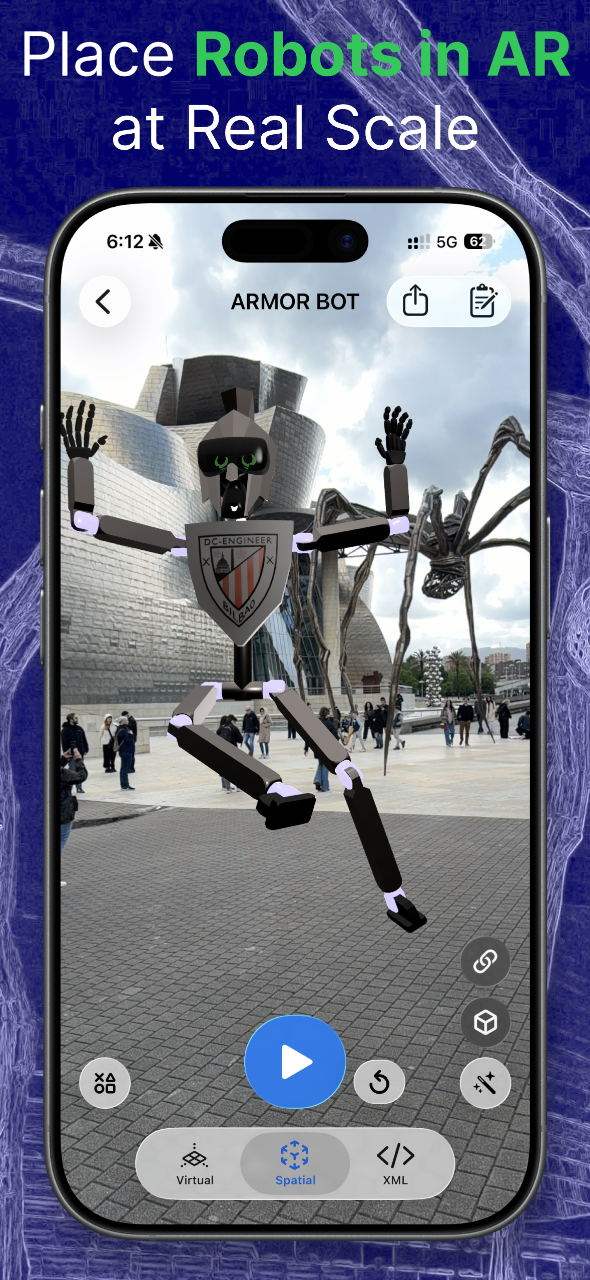
- AR placement at 1:1 scale for real-world spatial/safety assessment
- "Built by engineers, for engineers" — not a generic 3D viewer
Loading...
Related products
View all



More categories
All categories

Launched in Week 53, 2026
See the week
Send automated direct messages from Instagram keyword commen
0
Social Media, Marketing Automation, Lead Generation
0
Social Media, Marketing Automation, Lead Generation
55d18h1m
Launches in55days
:18hours
:01mins
:40secs
Budget app and expense tracker with 166 currencies
0
Personal Finance, Budgeting, Expense Tracking
0
Personal Finance, Budgeting, Expense Tracking
55d18h1m
Launches in55days
:18hours
:01mins
:40secs